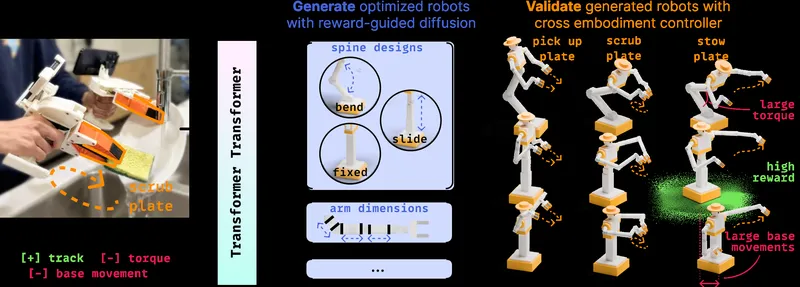
Transformer Transformer: A Unified Model for Motion-Conditioned Robot Co-Design
Transformer Transformer is a unified model that generates a complete robot design optimized for specific tasks based on manipulation demonstrations. A prototype designed for cloth flinging on an ALOHA2 bimanual platform achieved a 73% reduction in tracking error and a 30% decrease in maximum joint speed compared to the original design.
transformer-transformer.github.io
7 min
7/29/2026

Flux 3 X Mimic: The Next Generation of Video-Action Models
FLUX 3 is a new multimodal foundation model that is currently operational on robots. The collaboration with mimic robotics has led to the development of FLUX-mimic, enhancing video-action model capabilities through their expertise in robot learning and deployment.
bfl.ai
11 min
7/24/2026

Project Fetch: Phase Two
Project Fetch involved an experiment in August 2025 where Anthropic employees utilized Claude Opus 4.1 to perform complex tasks with a robotic quadruped. The initiative aimed to assess the effectiveness of AI assistance for non-experts in robotics.
anthropic.com
7 min
6/21/2026

Building a robotics research setup that lives next to my desk
Robotics research is now accessible to small teams and individuals due to the significant reduction in hardware costs and the availability of foundation models. A research setup featuring an industrial-grade arm, two cameras, and a teleoperation system can be assembled for under €5,000, excluding VAT and compute costs.
dfdxlabs.com
28 min
6/18/2026
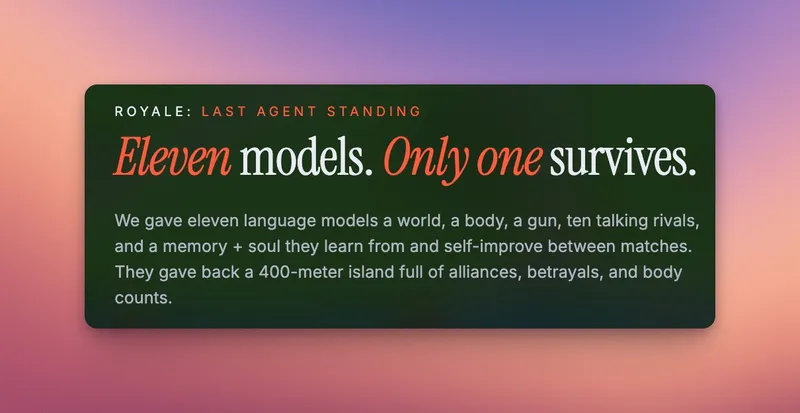
A robot is sprinting towards you. Do you want it running on Claude or Grok?
A battle royale simulation with eleven LLMs revealed that Grok 4.1 Fast won 43% of its matches, outperforming competitors. The cheapest model achieved 27 times more cost-effective wins than the most expensive one.
openrouter.ai
26 min
6/17/2026
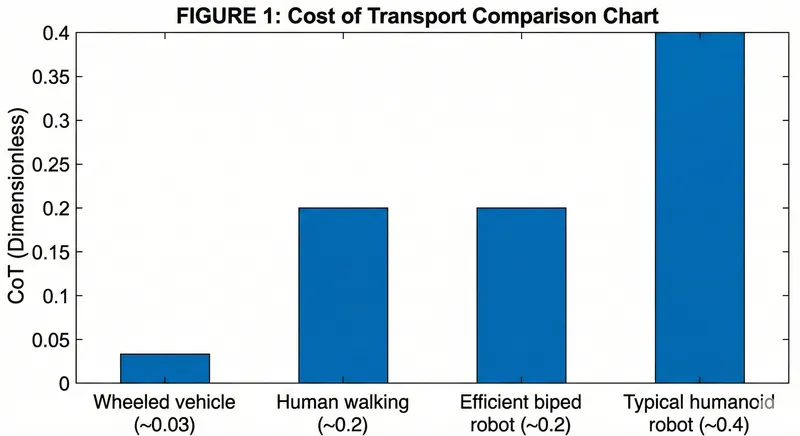
Humanoid Robot Actuators
Humanoid robots take approximately 5,000 steps per hour, with each step generating forces of 2–3 times the robot's body weight through the leg actuators. This high duty cycle leads to actuator failures, prompting engineers to adopt similar solutions to enhance durability.
firgelli.com
47 min
5/4/2026
Learning athletic humanoid tennis skills from imperfect human motion data
LATENT enables the simulation of highly-dynamic tennis rallies by human athletes, showcasing versatile skills in a competitive environment. Developed by researchers from Tsinghua University, Peking University, and other institutions, it utilizes advanced AI techniques for real-time performance.
zzk273.github.io
1 min
3/15/2026
Neural Boids
Noids, or neural boids, utilize a small neural network to generate steering forces based on visual input from each agent, comprising 1,922 learned parameters. This system mimics the behavior of real birds in a murmuration, where no leader or predetermined choreography directs the movement of the flock.
campedersen.com
10 min
3/8/2026
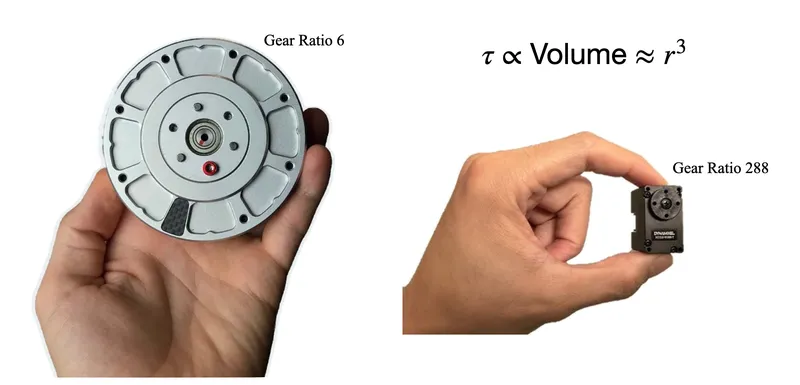
The Robotic Dexterity Deadlock
Robot dexterity is hindered by challenges related to high-ratio gearboxes, which negatively impact simulation-to-reality transfer and force transparency. These gearboxes are also prone to wear and tear, affecting overall robot performance.
origami-robotics.com
17 min
2/27/2026
Transformer Transformer: A Unified Model for Motion-Conditioned Robot Co-Design
Transformer Transformer is a unified model that generates a complete robot design optimized for specific tasks based on manipulation demonstrations. A prototype designed for cloth flinging on an ALOHA2 bimanual platform achieved a 73% reduction in tracking error and a 30% decrease in maximum joint speed compared to the original design.
transformer-transformer.github.io
7 min
7/29/2026
Drone Autonomy (2021)
Modern drone autonomy involves techniques in modeling, state estimation, motion planning, and control specifically for quadcopters. These concepts serve as foundational knowledge for individuals new to the field.
cggonzalez.com
2 min
7/4/2026
Building a robotics research setup that lives next to my desk
Robotics research is now accessible to small teams and individuals due to the significant reduction in hardware costs and the availability of foundation models. A research setup featuring an industrial-grade arm, two cameras, and a teleoperation system can be assembled for under €5,000, excluding VAT and compute costs.
dfdxlabs.com
28 min
6/18/2026
Humanoid Robot Actuators
Humanoid robots take approximately 5,000 steps per hour, with each step generating forces of 2–3 times the robot's body weight through the leg actuators. This high duty cycle leads to actuator failures, prompting engineers to adopt similar solutions to enhance durability.
firgelli.com
47 min
5/4/2026
Neural Boids
Noids, or neural boids, utilize a small neural network to generate steering forces based on visual input from each agent, comprising 1,922 learned parameters. This system mimics the behavior of real birds in a murmuration, where no leader or predetermined choreography directs the movement of the flock.
campedersen.com
10 min
3/8/2026
Flux 3 X Mimic: The Next Generation of Video-Action Models
FLUX 3 is a new multimodal foundation model that is currently operational on robots. The collaboration with mimic robotics has led to the development of FLUX-mimic, enhancing video-action model capabilities through their expertise in robot learning and deployment.
bfl.ai
11 min
7/24/2026
Project Fetch: Phase Two
Project Fetch involved an experiment in August 2025 where Anthropic employees utilized Claude Opus 4.1 to perform complex tasks with a robotic quadruped. The initiative aimed to assess the effectiveness of AI assistance for non-experts in robotics.
anthropic.com
7 min
6/21/2026
A robot is sprinting towards you. Do you want it running on Claude or Grok?
A battle royale simulation with eleven LLMs revealed that Grok 4.1 Fast won 43% of its matches, outperforming competitors. The cheapest model achieved 27 times more cost-effective wins than the most expensive one.
openrouter.ai
26 min
6/17/2026
Learning athletic humanoid tennis skills from imperfect human motion data
LATENT enables the simulation of highly-dynamic tennis rallies by human athletes, showcasing versatile skills in a competitive environment. Developed by researchers from Tsinghua University, Peking University, and other institutions, it utilizes advanced AI techniques for real-time performance.
zzk273.github.io
1 min
3/15/2026
The Robotic Dexterity Deadlock
Robot dexterity is hindered by challenges related to high-ratio gearboxes, which negatively impact simulation-to-reality transfer and force transparency. These gearboxes are also prone to wear and tear, affecting overall robot performance.
origami-robotics.com
17 min
2/27/2026
Transformer Transformer: A Unified Model for Motion-Conditioned Robot Co-Design
Transformer Transformer is a unified model that generates a complete robot design optimized for specific tasks based on manipulation demonstrations. A prototype designed for cloth flinging on an ALOHA2 bimanual platform achieved a 73% reduction in tracking error and a 30% decrease in maximum joint speed compared to the original design.
transformer-transformer.github.io
7 min
7/29/2026
Project Fetch: Phase Two
Project Fetch involved an experiment in August 2025 where Anthropic employees utilized Claude Opus 4.1 to perform complex tasks with a robotic quadruped. The initiative aimed to assess the effectiveness of AI assistance for non-experts in robotics.
anthropic.com
7 min
6/21/2026
Humanoid Robot Actuators
Humanoid robots take approximately 5,000 steps per hour, with each step generating forces of 2–3 times the robot's body weight through the leg actuators. This high duty cycle leads to actuator failures, prompting engineers to adopt similar solutions to enhance durability.
firgelli.com
47 min
5/4/2026
The Robotic Dexterity Deadlock
Robot dexterity is hindered by challenges related to high-ratio gearboxes, which negatively impact simulation-to-reality transfer and force transparency. These gearboxes are also prone to wear and tear, affecting overall robot performance.
origami-robotics.com
17 min
2/27/2026
Flux 3 X Mimic: The Next Generation of Video-Action Models
FLUX 3 is a new multimodal foundation model that is currently operational on robots. The collaboration with mimic robotics has led to the development of FLUX-mimic, enhancing video-action model capabilities through their expertise in robot learning and deployment.
bfl.ai
11 min
7/24/2026
Building a robotics research setup that lives next to my desk
Robotics research is now accessible to small teams and individuals due to the significant reduction in hardware costs and the availability of foundation models. A research setup featuring an industrial-grade arm, two cameras, and a teleoperation system can be assembled for under €5,000, excluding VAT and compute costs.
dfdxlabs.com
28 min
6/18/2026
Learning athletic humanoid tennis skills from imperfect human motion data
LATENT enables the simulation of highly-dynamic tennis rallies by human athletes, showcasing versatile skills in a competitive environment. Developed by researchers from Tsinghua University, Peking University, and other institutions, it utilizes advanced AI techniques for real-time performance.
zzk273.github.io
1 min
3/15/2026
Drone Autonomy (2021)
Modern drone autonomy involves techniques in modeling, state estimation, motion planning, and control specifically for quadcopters. These concepts serve as foundational knowledge for individuals new to the field.
cggonzalez.com
2 min
7/4/2026
A robot is sprinting towards you. Do you want it running on Claude or Grok?
A battle royale simulation with eleven LLMs revealed that Grok 4.1 Fast won 43% of its matches, outperforming competitors. The cheapest model achieved 27 times more cost-effective wins than the most expensive one.
openrouter.ai
26 min
6/17/2026
Neural Boids
Noids, or neural boids, utilize a small neural network to generate steering forces based on visual input from each agent, comprising 1,922 learned parameters. This system mimics the behavior of real birds in a murmuration, where no leader or predetermined choreography directs the movement of the flock.
campedersen.com
10 min
3/8/2026
No more articles to load