Transformer Transformer: A Unified Model for Motion-Conditioned Robot Co-Design
transformer-transformer.github.io
July 29, 2026
7 min read
🔥🔥🔥🔥🔥
47/100
Summary
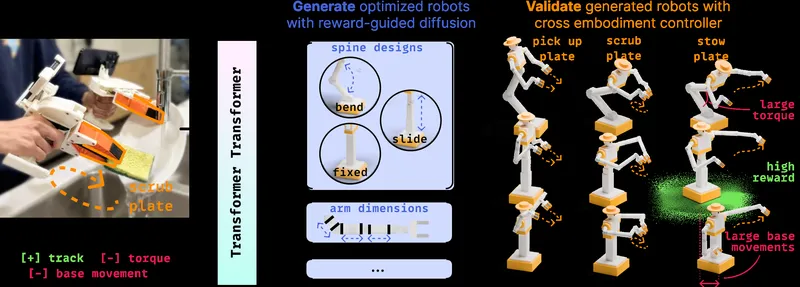
Transformer Transformer is a unified model that generates a complete robot design optimized for specific tasks based on manipulation demonstrations. A prototype designed for cloth flinging on an ALOHA2 bimanual platform achieved a 73% reduction in tracking error and a 30% decrease in maximum joint speed compared to the original design.
Key Takeaways
- Transformer Transformer is a unified model that generates optimized robot embodiments for specific tasks based on manipulation demonstrations, improving performance metrics significantly.
- The model employs a diffusion transformer trained on RoboTokens, allowing it to span various robot embodiments and control tasks without overfitting to a single reward function.
- The framework for robot co-design consists of three steps: demonstrating desired motion, generating an optimized robot embodiment, and validating the design through direct control.
- RoboTokens serve as a shared vocabulary for robot design, enabling the representation of various robot attributes and dynamics in a unified manner.
Coverage & discussions
Hacker News · transformer-transformer.github.io
Community discussions
Hacker News discussion ↗
Historical count: 3 · 3 saved in sample · Historical sample
Awaiting analysis